Haptic Exoskeleton and Teleoperated Robot Arm
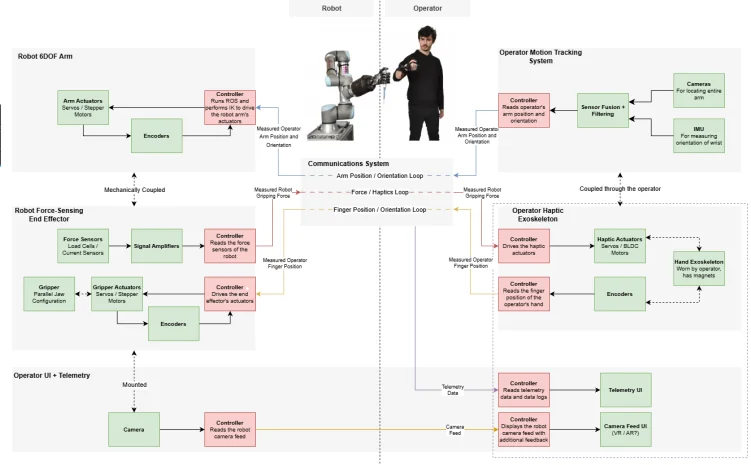
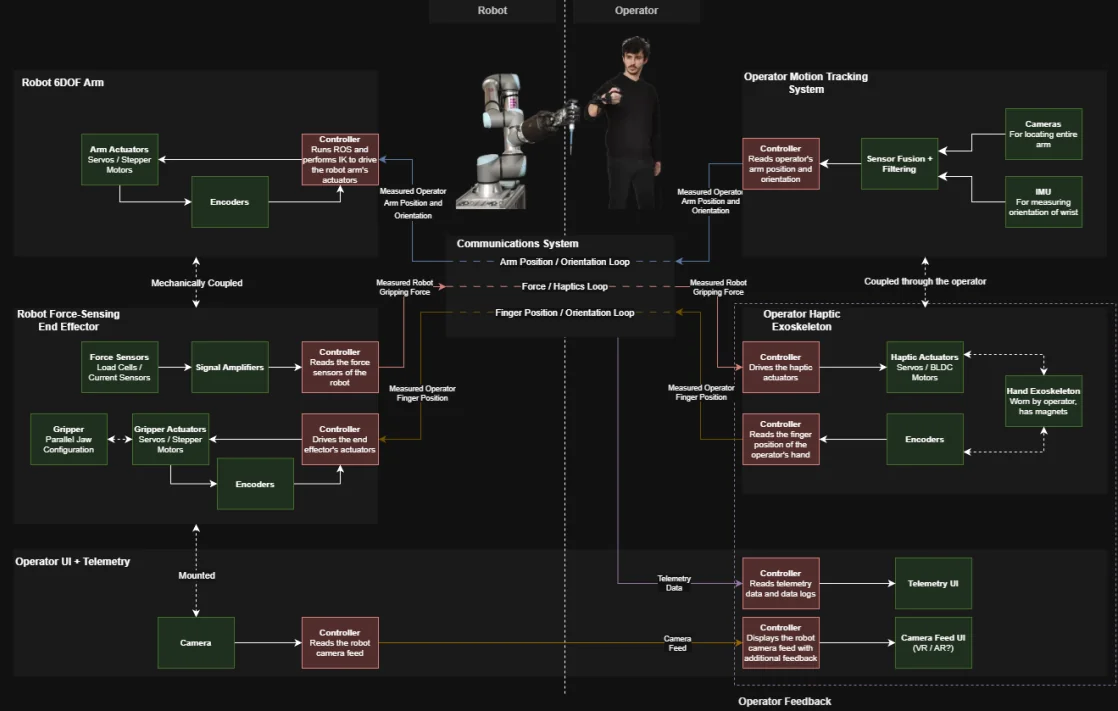
HETRA (Haptic Exoskeleton & Teleoperated Robot Arm) is a teleoperation system that lets an operator control a remote 6-DoF robot arm with their own arm and physically feel what it is holding. A wearable tracker turns the operator's arm movements into robot motion, and a haptic hand exoskeleton maps the robot's contact forces back onto the operator's fingers. The project explores human-robot interaction, haptics, and wearable exoskeletons.
Goals
HETRA gives students hands-on experience across the full robotics stack: mechanical design of wearable linkages, grippers, and robot joints, electrical work on custom PCBs, sensors, and motor control, firmware for haptic rendering and sensor fusion, and software for computer vision, inverse kinematics, ROS, and low-latency networking.
Ideas
Most teleoperation relies on vision alone, yet research shows haptic feedback leads to better force control, faster task completion, and fewer errors. HETRA brings the sense of touch to remote manipulation, which matters wherever direct human presence is dangerous or impossible, such as bomb disposal, space, and surgery.
Objective
Build a bilateral teleoperation system where the operator's movements drive the robot arm and the robot's contact forces are rendered back to the operator, fast and stable enough that touching a hard surface feels immediate.
Future
As the subsystems come together, the team will integrate them into a complete teleoperation system, with a live telemetry dashboard to monitor system health, sensor data, and tracking status.
System Architecture